docs.unavlab.com
Main ❯ Navigation & tracking systems ❯ RWLT GIB: Device specification
 |
 |
|---|---|
| www.unavlab.com support@unavlab.com |
RWLT GIB - Navigation buoy Device specification |
KEY FEATURES
- High-performance combined GPS/GLONASS receiver
- Rugged, durable, easily noticeable housing
- Automatic activation in water
- Long battery life of up to 24 hours
- Reliable and noise-resistant digital broadband underwater acoustic communication technology
DESCRIPTION
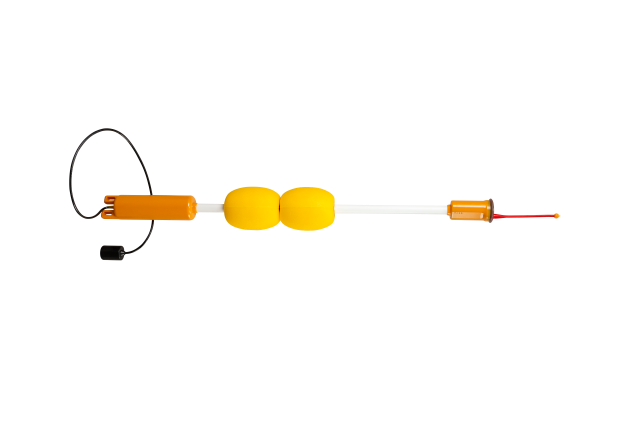
The RWLT GIB navigation sonobuoy of the RWLT system, in a set of four such devices, forms a floating long navigation base that supports positioning of the RWLT Pinger pinger or the RedPhone diver telephone station.
The device has a float-and-spar (spar buoy) design and has no air cavities or controls: it switches on automatically when immersed in water, and switches off automatically when the buoy is taken out of the water.
TECHNICAL SPECIFICATIONS
| PARAMETER | VALUE |
|---|---|
| DIMENSIONS1 (Ø x h) | 130 x 1350 mm |
| WEIGHT (dry) | 3.7 kg |
| EXCESS BUOYANCY | 1 kg |
| CARRIER FREQUENCY | 20050 Hz |
| MAXIMUM BATTERY LIFE2 | 12 hours |
| MAXIMUM VELOCITY RELATIVE TO PINGER | ± 1.8 m/s |
| OPERATING TEMPERATURE RANGE | -10 .. 50 °C |
| MAXIMUM ACOUSTIC COMMUNICATION RANGE3 | 3000 m |
| MAXIMUM PERMISSIBLE DISTANCE TO OTHER BUOYS OF THE SET4,5 | 1500 m |
| MINIMUM PERMISSIBLE DISTANCE TO OTHER BUOYS OF THE SET5 | 30 m |
| REFERENCE ELLIPSOID | WGS-84 |
| BUILT-IN BATTERY TYPE | LiFePO4 |
| BUILT-IN BATTERY CAPACITY | 76 W·h |
| HEIGHT ABOVE WATER (fresh water) | 730 mm |
| DRAFT (fresh water) | 1655 mm |
| TRANSDUCER CABLE LENGTH | 960 mm |
| BUILT-IN RADIO MODULE TYPE | GFSK, 433 MHz |
| MAXIMUM RADIO MODULE POWER | 100 mW |
| MAXIMUM RADIO COMMUNICATION RANGE6 | 1000 m |
ADDITIONAL INFORMATION
| MSDS OF THE BUILT-IN POWER SUPPLY | ELECTRONIC VERSION OF THIS DOCUMENT |
|---|---|
1 Not including the receiving transducer on the cable, with a total length of 1.6 m.
2 With a new, fully charged battery, at an ambient temperature of 20 °C.
3 A parameter that determines the maximum range at which signal reception is possible, based on the electro-acoustic parameters of the transmitter and receiver, the spatial decrease in the intensity of sound energy, attenuation in the medium and the acoustic noise level.
4 The buoys are placed on the water surface in a convex polygon so that the distance from each buoy to any other does not exceed the specified value.
5 The immersion depth of the pinger must not exceed the dimensions of the navigation base.
6 Achieved in the absence of interference, in open areas.