[Main](/) ❯ [Navigation & tracking systems](/navigation_and_tracking_systems_en) ❯ **Zima2-R: Device specification**
ℹ Recommendations for printing / saving as PDF
- Press Ctrl+P (macOS: Cmd+P)
- Select "Save as PDF" (Microsoft Print to PDF) as the printer
- In "Pages", enter a range that excludes the first and the last page
- Disable headers and footers (title, URL, page numbers)
- In Chrome/Edge: More settings → "Margins" → None | in Firefox: "Margins & Header/Footer" → None
- Click Print and choose where to save the PDF
|  |  |
| :---: | ---: |
| [www.unavlab.com](https://www.unavlab.com/)
[support@unavlab.com](mailto:support@unavlab.com) | **Zima2-R** - **Zima2 USBL** responder-beacon
Device specification |
## KEY FEATURES
* **Extremely small size and weight**
* **Communication range up to 3000[1](#footnote1) m**
* **Highly reliable digital underwater acoustic communication resistant to multipath propagation**
* **Code division multiple access - up to 16 isolating addresses**
* **Low power consumption (Rx/Tx) 0.33/10 W**
* **Built-in pressure/temperature sensor**
* **Patented[*](#footnote_a1) monoblock design**
## DESCRIPTION
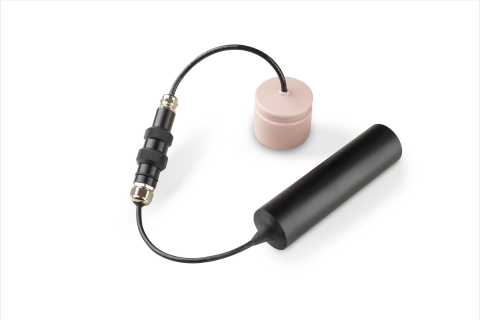
**Zima2-R** - responder-beacon of the ultra-short baseline navigation system [Zima2 USBL](Zima2_DataBrief_en.md).
The device is designed to be placed on an underwater object in order to determine the location of this object in real time using the direction-finding antenna [Zima2-B](Zima2B_Specification_en.md).
The device can be either standalone (with an additional [battery pack](/documentation/EN/Accessories/Sub_batteries_en#sb2448lf)) or interfaced with the carrier for power.
Extremely small size, ease of use and low power consumption make the direction-finding system [Zima2 USBL](Zima2_DataBrief_en.md) an ideal solution for working with autonomous and remotely controlled vehicles, as well as for determining the relative position of divers.
________________
* Patent RU2659299C1.
## TECHNICAL SPECIFICATIONS
| PARAMETER | VALUE |
| :--- | :--- |
| DIMENSIONS (Ø x h) | 64 x 62 mm |
| WEIGHT (dry)[2](#footnote2) | 0.3 kg |
| MAXIMUM DEPTH | 300 m |
| DEPTH RESOLUTION | 0.6 m |
| MAXIMUM ACOUSTIC COMMUNICATION RANGE[1](#footnote1) | 3000 m |
| ACOUSTIC SOURCE LEVEL | 170 dB re 1 μPa @ 1 m |
| CARRIER FREQUENCY | 20100 Hz |
| BUILT-IN TEMPERATURE SENSOR ACCURACY | 0.1°C |
| SUPPLY VOLTAGE | 12 V |
| DATA LINE VOLTAGE | 0 .. 3.3 V |
| BIT ERROR RATE | 10-6 |
| SNR[3](#footnote3) | -3 dB |
| MAXIMUM RELATIVE VELOCITY | ± 2 m/s |
| STARTUP TIME | 100 ms |
| OPERATING TEMPERATURE RANGE | -5 .. 50 °C |
| POWER CONSUMPTION (Rx/Tx) | 0.33 / 10 W |
| INTERFACE | UART 9600 bit/s |
| COMMUNICATION PROTOCOL | NMEA 0183 [PAZM](Zima2_Protocol_Specification_en.md) |
| CABLE LENGTH[4](#footnote4) | 0.5 m |
| MAXIMUM NUMBER OF ADDRESSES | 16 |
________________
- 1 A parameter that determines the maximum range at which a signal can be received, based on electro-acoustic parameters of the transmitter and receiver, spatial decrease in the intensity of sound energy, attenuation in the medium and the acoustic noise level.
- 2 Excluding the weight of the battery pack. Standard battery pack [SB-24-48-LF](/documentation/EN/Accessories/Sub_batteries_en#sb2448lf).
- 3 The value was obtained in a laboratory static experiment, without taking into account the multipath propagation effect.
- 4 The value can be changed on request.
- 5 Obtained in laboratory conditions in a static experiment.
## ADDITIONAL INFORMATION
In the standalone version, the device is equipped with the battery pack [SB-24-48-LF](/documentation/EN/Accessories/Sub_batteries_en#sb2448lf) based on LiFePO4 (lithium iron phosphate) batteries, which provide more than a thousand charge-discharge cycles and operation at low ambient temperatures.
The responder-beacon is connected to the battery pack through a sealed connector, which additionally provides the function of automatically switching the device on when it is immersed in water.
The operating time of the responder-beacon on the battery pack depends on the intensity of the exchange with the direction-finding antenna, which in turn depends on the range, the number of responder-beacons polled by the direction-finding antenna and the hydrological conditions.
### BATTERY LIFE
| POLLING PERIOD, s | OPERATING TIME, h | NOTE |
| :---: | :---: | :--- |
| - | 70 | Without polling, in receiving mode |
| 1 | 8 | Shortest possible polling period |
| 2 | 16 | |
| 4 | 32 | |
| 8 | 64 | |
| 16 | up to 70 | |
### CABLE WIRE ASSIGNMENT (In the integrated version)
| WIRE COLOR | FUNCTION |
| :--- | :---: |
| 🟥 Red | + Usupply |
| 🟩 Green | Tx |
| ⬜ White/Transparent | Rx |
| 🟨 Yellow | SVC |
| Shield | - Usupply |